Yuxian Li

李昱贤

I'm a final-year Computer Engineering undergraduate at the University of Hong Kong and a research intern in the InfoBodied AI Lab, mentored by Prof. Yanchao Yang.

I'm interested in how to steer AI to continuously learn from messy, heterogeneous physical-world data, and designing the low-level compute infrastructure to scale it.

I'm exploring research collaborations and PhD opportunities for Fall 2027.

News

  • CAFE was accepted to NeurIPS 2026, Evaluations & Datasets Track (Poster).
  • Joined OneRobotics as a research intern working on multimodal foundation models.
  • Received an Outstanding Poster Award at HKU ECE Poster Display Day.

Publications

* Equal contribution
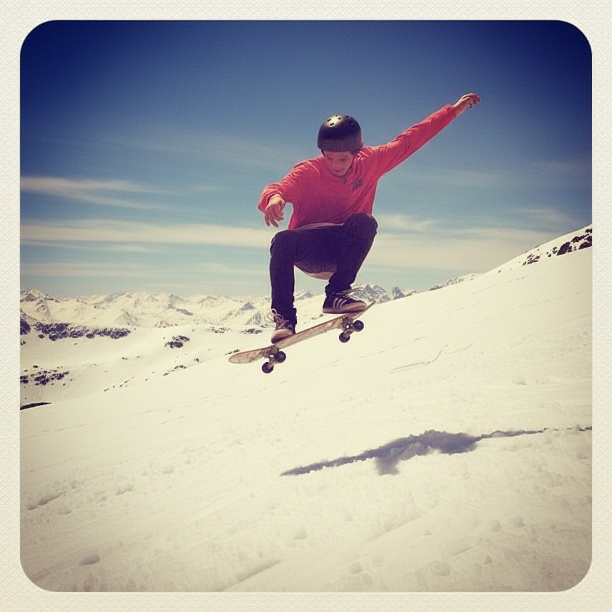
A CAFE counterfactual example: a skateboarder in a snowy scene, still riding a wheeled skateboard.
A skateboarder, even in the snow.
CAFE · CC BY-SA 4.0

From Pixels to Concepts: Do Segmentation Models Understand What They Segment?

Shuang Liang*, Zeqing Wang*, Yuxian Li*, Xihui Liu, Han Wang
NeurIPS 2026 · Evaluations & Datasets Track (Poster)

A correct mask can still reflect the wrong concept. CAFE tests this with 2,146 paired examples that introduce misleading appearance, context, or material cues while preserving the target region and mask.

My contribution

I co-curated the benchmark and built CAFE-SAM3, an agent that inspects regions, refines prompts, and selects a matching mask or abstains. I also led follow-up evaluation and failure analysis, with mentoring from Profs. Xihui Liu and Han Wang.

BibTeX
@inproceedings{liang2026pixels,
  title = {From Pixels to Concepts: Do Segmentation Models Understand What They Segment?},
  author = {Liang, Shuang and Wang, Zeqing and Li, Yuxian and Liu, Xihui and Wang, Han},
  booktitle = {Advances in Neural Information Processing Systems (NeurIPS), Evaluations \& Datasets Track},
  year = {2026},
  url = {https://arxiv.org/abs/2605.09591}
}
Projects

Flow-based action generation.

Action models for robot learning

Research with HKU CASIC · Manuscript under review

I work on the action-generating part of vision-language-action models, connecting architecture design with policy learning and closed-loop behavior.

My contribution

Supervised by Prof. Han Wang, I led action-head design, distillation, training, and evaluation, and built the real-robot setup and data-collection pipeline. The public implementation below covers flow-based policies in LeRobot.

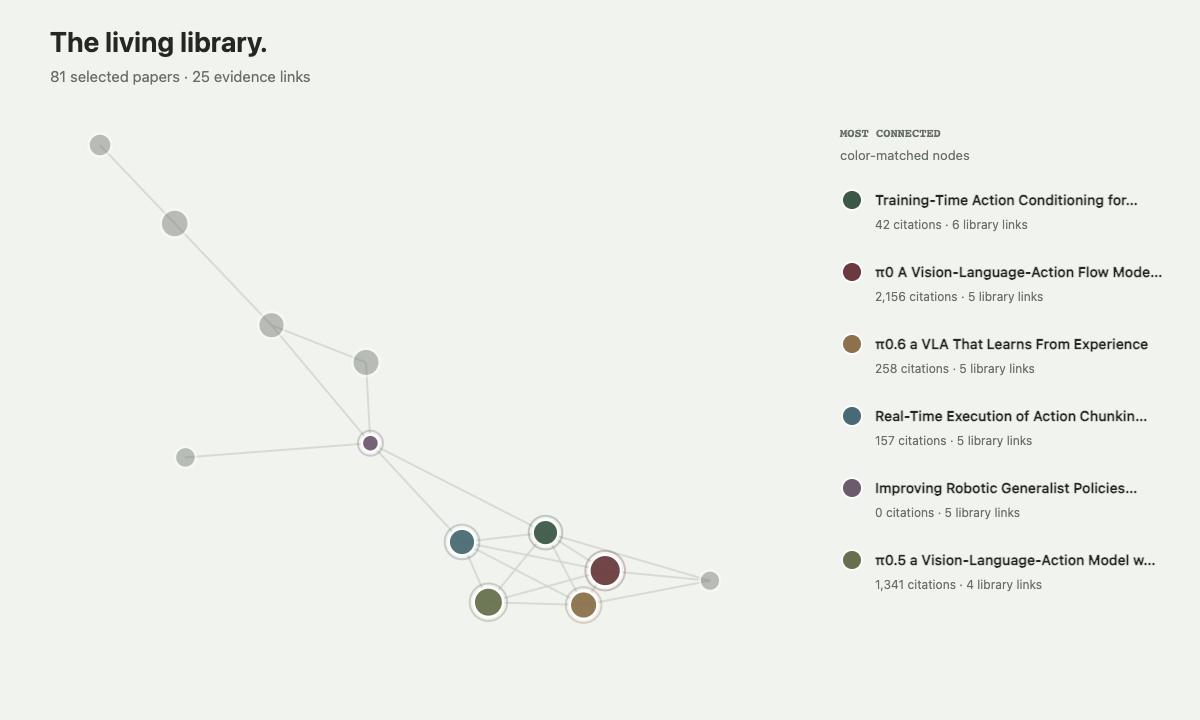
An example Scholar MCP library, with papers connected by citation and evidence links.
A paper library with citation and evidence links.

Scholar MCP

Open-source research tool

Research infrastructure for agentic auto-research, connecting literature search, paper reading, citation exploration, and a persistent library with source provenance.

My contribution

I built the retrieval and library system around unified paper records, helping agents refine searches and reuse source-linked findings across long-running research sessions.

Reveal StarMap

A released Oxygen Not Included mod for previewing the star map while preserving saved exploration and camera state.

MediBot

A team project in mobile robot sensing, motion control, navigation, and remote monitoring.

Experience

InfoBodied AI Lab, HKU

Research Intern · Prof. Yanchao Yang

Human-signal-guided representations for robot policy learning, with work on temporal alignment, learning objectives, and ablations.

2026

OneRobotics

Research Intern · Multimodal Foundation Models

Online RL for humanoid loco-manipulation and multimodal pretraining for vision-language-action and world-action models.

Aug–Sep 2026

CASIC, HKU

Research Assistant · Prof. Han Wang

Action-model architecture, knowledge distillation, and real-robot evaluation, in collaboration with circuit and chip designers.

2025

Education

The University of Hong Kong

BEng in Computer Engineering

Outstanding Poster Award · HKU ECE Poster Display Day, 2026

University of California, Berkeley

Summer Session · CS 61B, Data Structures

Outside research, I enjoy visual art, Chinese calligraphy, freeride snowboarding, and playing guitar.